Robotic spider
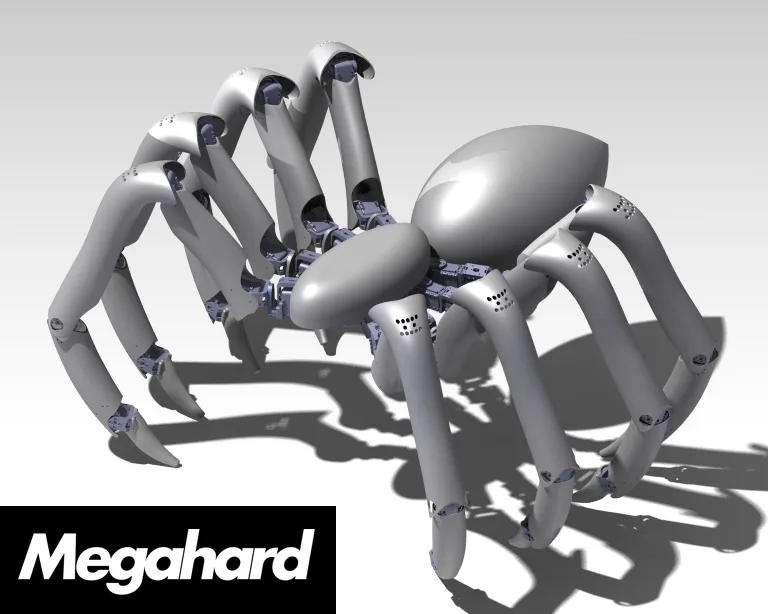
This robot spider was designed for fun, to show off Megahard's mechanical CAD capabilities. A biological spider, and hence also this robot spider, can navigate terrain that is impassable for most other land vehicles. The legs of the robot spider have at least the same freedom of movement as those of a biological spider.
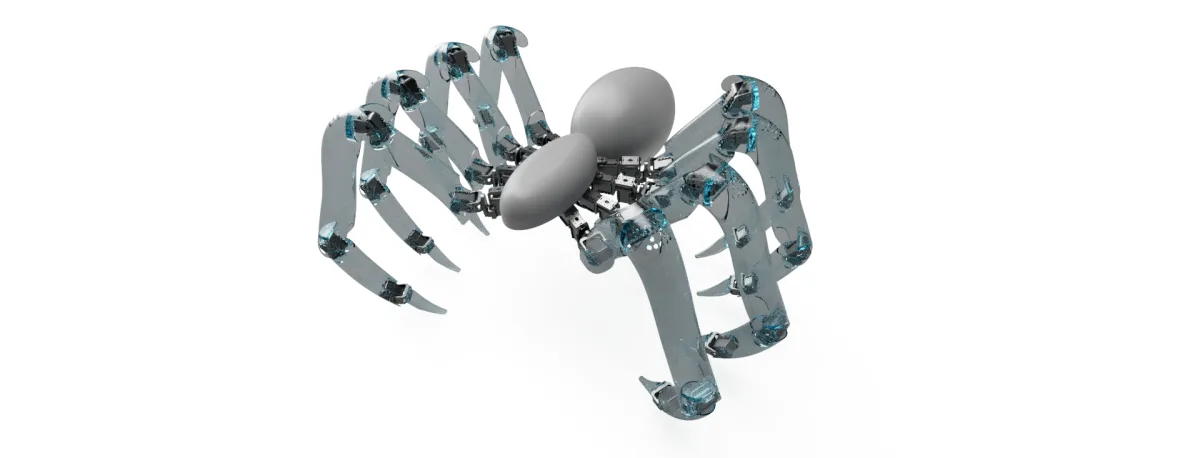
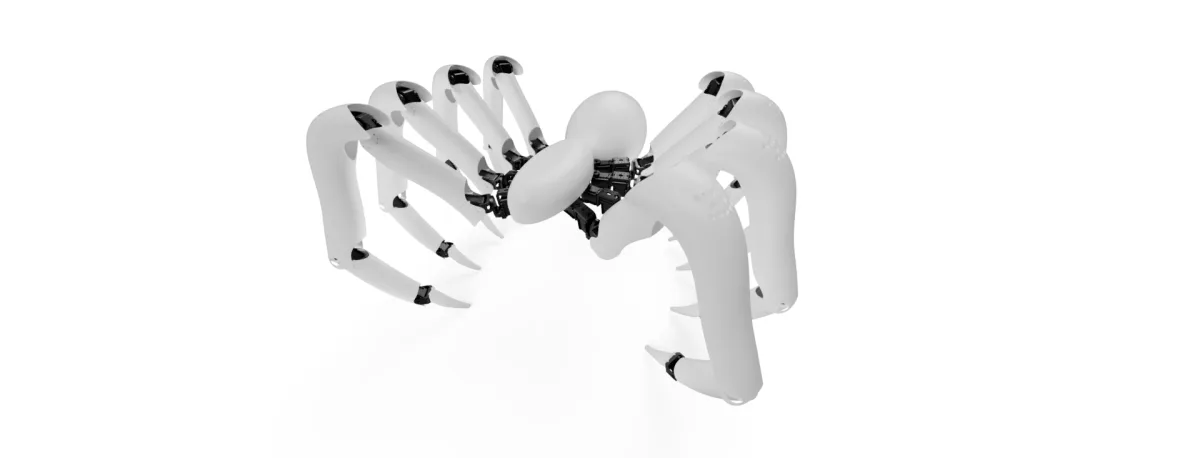
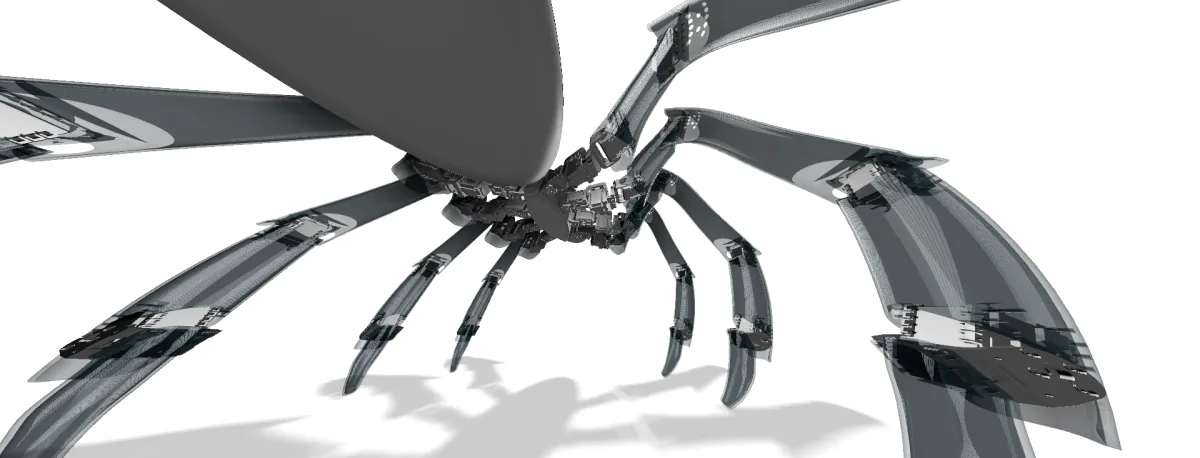
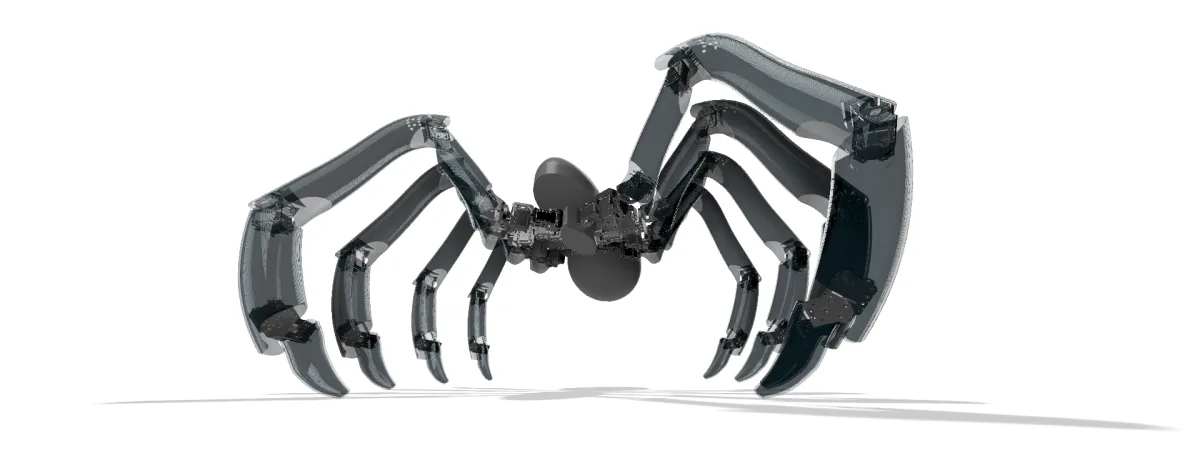
Free and open-source design
If you'd like to contribute or start your own robot project based on this design, feel free. The project is work in progress. The mechanical CAD files are on GitLab: gitlab.com/Megahard.pro/spider-robot-cad. Megahard would love to hear from you if you use the design files.
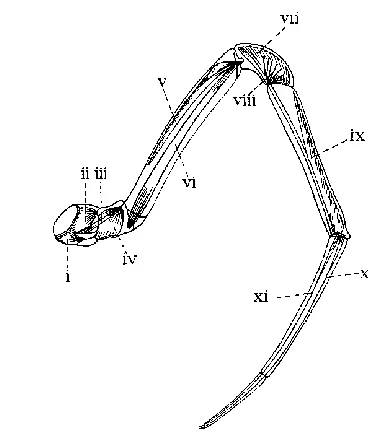
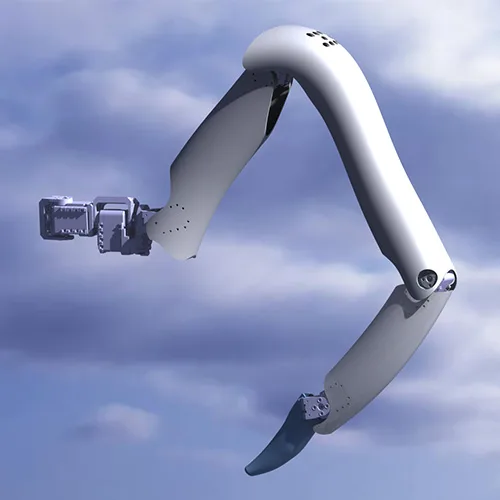
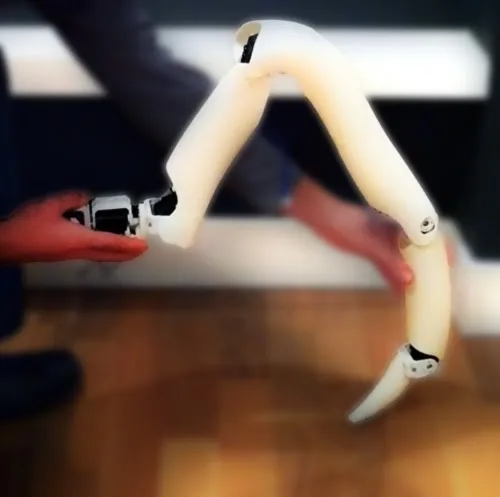
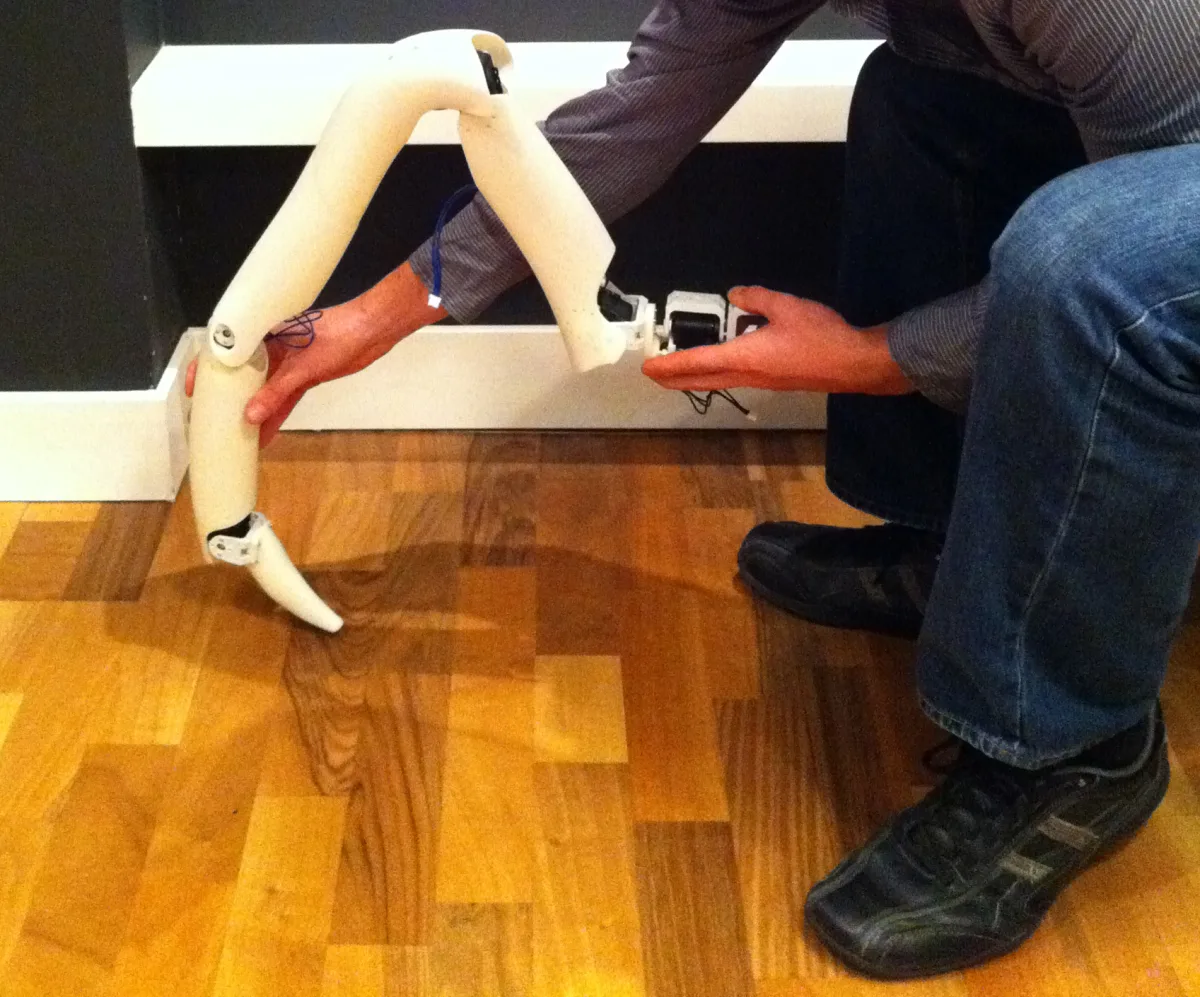
From a biological leg to a 3D printed leg
Applications in the real world
- Exploring areas that are dangerous or rough for humans: searching for survivors after a nuclear disaster, exploring war zones, inspecting unstable buildings after an earthquake, tsunami or volcanic eruption.
- Crisis response, to avoid risking human lives.
- Defusing bombs such as land mines. Tracked robots do this today; a robot spider could reach more impassable areas.
- Guarding property.
Analysing spider motion
The next step is the algorithm that lets the mechanical spider move and navigate, which means studying the motion, intelligence and control system of a real spider. One source is motion capture video and data of a tarantula, created by Christian Kickenweitz for his thesis at the University of Applied Sciences in Stuttgart, Germany (2006).
Working on something similar? Megahard designs the electronics, firmware, enclosure and software, from idea to working prototype.
Start a project